

Fully Autonomous Quadruped Robot Dog Controller
Classification: Robot Body Solutions
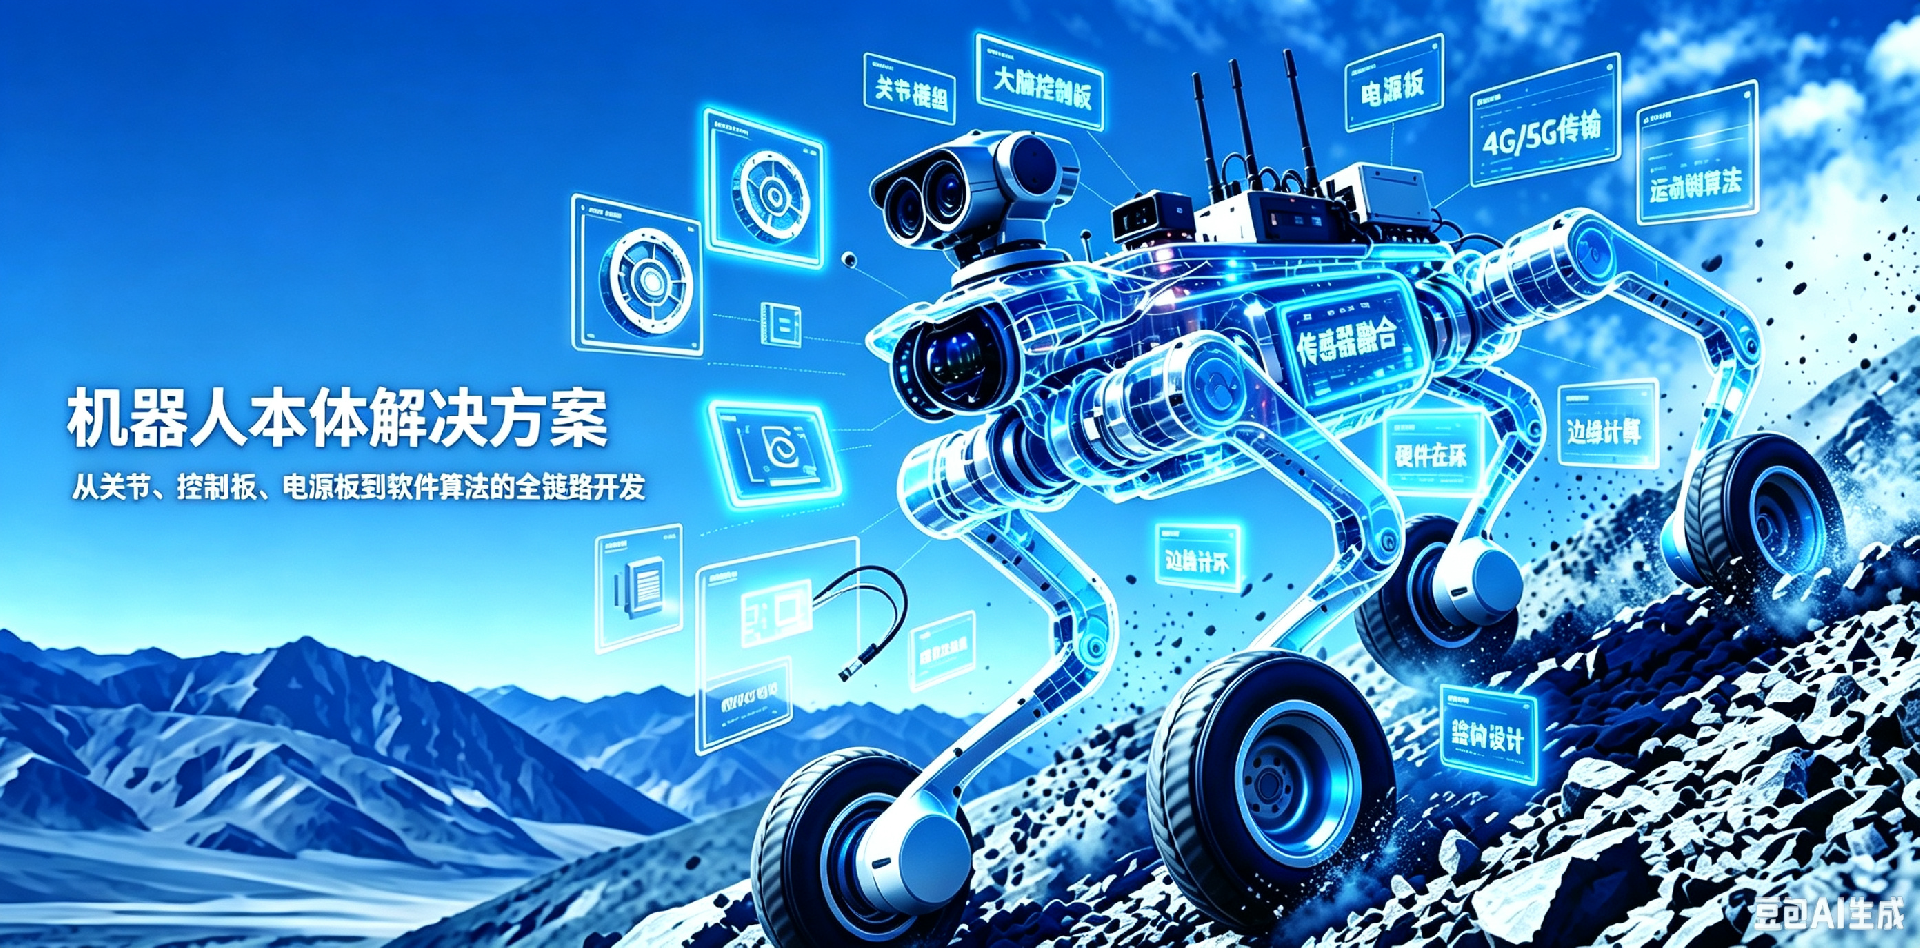
Product introduction:The team builds the quadruped robot dog system architecture based on ROS (Robot Operating System), with excellent secondary development and functional expansion capabilities; independently develops high-performance controllers based on the RK3588 chip, providing precise and reliable motion control support for quadruped robot dogs; self-developed joint modules use FOC (Field Oriented Control) algorithms for driver design, significantly improving stability and smoothness during robot dog movement. Currently, the quadruped robot dog complete machine, core controller, and joint modules have all completed prototype development and entered the functional verification and performance optimization phase.
